

What is the inertia of a Cnc Robot Arm?
In the realm of industrial automation, CNC robot arms have emerged as indispensable tools, revolutionizing manufacturing processes across various industries. As a leading [company's role, e.g., "CNC robot arm supplier"], I've witnessed firsthand the transformative power of these sophisticated machines. One critical aspect that often goes unnoticed but significantly impacts the performance of a CNC robot arm is its inertia. In this blog post, we'll delve into the concept of inertia in CNC robot arms, exploring its implications, factors influencing it, and how it affects the overall operation of these remarkable devices.
Understanding Inertia
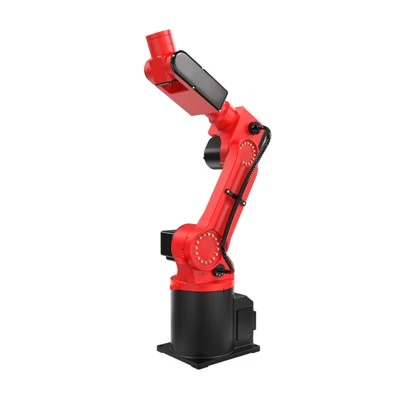
Inertia, in the context of physics, is the property of an object to resist changes in its state of motion. In the case of a CNC robot arm, inertia refers to the resistance it offers to changes in its velocity or direction of movement. This resistance is primarily determined by the mass of the robot arm and the distribution of that mass relative to its axis of rotation.
The formula for calculating the moment of inertia (I) of a rigid body is given by:
[ I = \sum_{i} m_{i} r_{i}^{2} ]
where ( m_{i} ) is the mass of the ( i^{th} ) particle in the body, and ( r_{i} ) is the perpendicular distance of the ( i^{th} ) particle from the axis of rotation.
For a CNC robot arm, the moment of inertia plays a crucial role in determining how quickly the arm can accelerate, decelerate, and change its direction. A higher moment of inertia means that the arm requires more torque to achieve the same acceleration or deceleration compared to an arm with a lower moment of inertia.
Factors Influencing the Inertia of a CNC Robot Arm
Several factors contribute to the inertia of a CNC robot arm. Understanding these factors is essential for optimizing the design and performance of the arm.
-
Mass of the Arm: The total mass of the robot arm is one of the primary factors influencing its inertia. A heavier arm will have a higher moment of inertia, making it more difficult to accelerate and decelerate. Manufacturers often strive to reduce the mass of the arm without compromising its strength and rigidity to improve its dynamic performance.
-
Mass Distribution: The distribution of mass within the robot arm also plays a significant role in determining its inertia. A robot arm with a more centralized mass distribution will have a lower moment of inertia compared to an arm with a more spread-out mass distribution. Designers carefully consider the placement of components such as motors, gears, and sensors to minimize the moment of inertia and improve the arm's responsiveness.
-
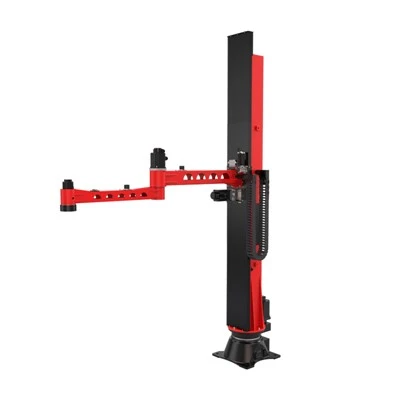
Length of the Arm: The length of the robot arm affects its moment of inertia. A longer arm will have a higher moment of inertia, as the mass is distributed farther from the axis of rotation. This can make it more challenging to control the arm's movement, especially at high speeds.
-
Payload: The payload carried by the robot arm also contributes to its inertia. A heavier payload will increase the overall mass of the arm, resulting in a higher moment of inertia. It's important to consider the payload capacity of the robot arm when selecting a model for a specific application.
Implications of Inertia on CNC Robot Arm Performance
The inertia of a CNC robot arm has several implications for its performance and operation.
-
Acceleration and Deceleration: A higher moment of inertia means that the robot arm requires more torque to accelerate and decelerate. This can result in slower response times and reduced productivity. Manufacturers may need to use more powerful motors or optimize the arm's design to overcome the effects of inertia and improve its acceleration and deceleration capabilities.
-
Precision and Accuracy: Inertia can also affect the precision and accuracy of the robot arm's movement. A higher moment of inertia can cause the arm to overshoot or undershoot its target position, leading to errors in the manufacturing process. To ensure precise and accurate movement, it's essential to carefully control the arm's inertia and use advanced control algorithms.
-
Energy Consumption: The inertia of the robot arm can also impact its energy consumption. A higher moment of inertia requires more energy to accelerate and decelerate the arm, resulting in increased power consumption. By reducing the arm's inertia, manufacturers can improve its energy efficiency and reduce operating costs.
-
Mechanical Stress: Inertia can also subject the robot arm to mechanical stress, especially during high-speed movements or sudden changes in direction. A higher moment of inertia can increase the stress on the arm's joints, bearings, and other components, leading to premature wear and failure. To minimize mechanical stress, it's important to design the arm with a low moment of inertia and use high-quality components.
Optimizing Inertia in CNC Robot Arms
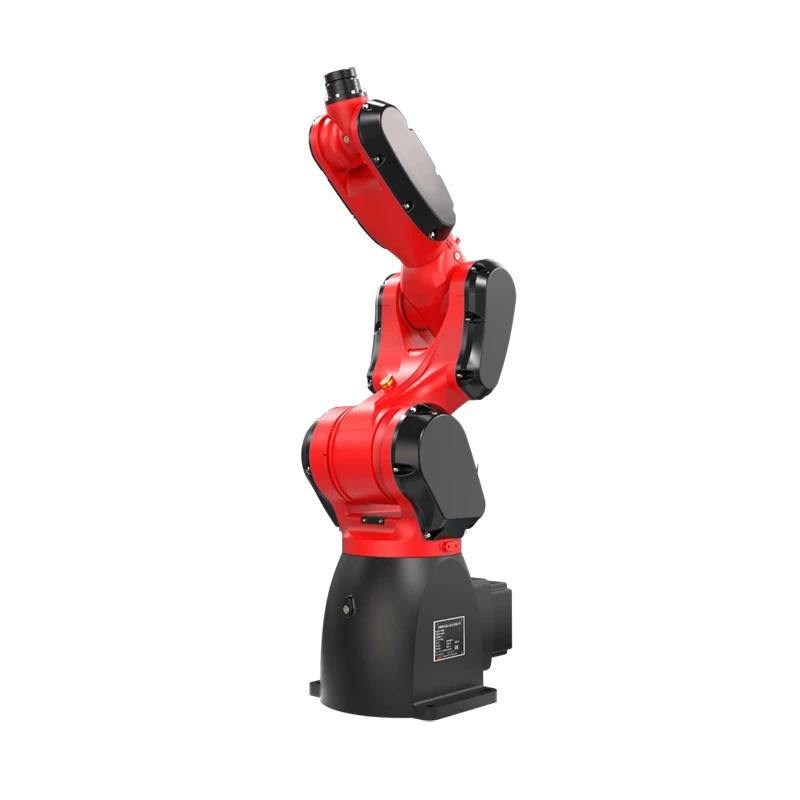
As a [company's role, e.g., "CNC robot arm supplier"], we understand the importance of optimizing the inertia of our products to ensure superior performance and reliability. Here are some strategies we employ to minimize the inertia of our CNC robot arms:
-
Lightweight Materials: We use lightweight materials such as aluminum and carbon fiber composites to reduce the mass of the robot arm without compromising its strength and rigidity. These materials offer excellent strength-to-weight ratios, allowing us to design arms with a lower moment of inertia.
-
Compact Design: We carefully design the robot arm to have a compact and centralized mass distribution. By minimizing the distance between the center of mass and the axis of rotation, we can reduce the moment of inertia and improve the arm's responsiveness.
-
Advanced Control Algorithms: We use advanced control algorithms to compensate for the effects of inertia and ensure precise and accurate movement. These algorithms can adjust the arm's speed and acceleration based on the load and the desired trajectory, minimizing overshoot and undershoot.
-
Payload Management: We provide our customers with guidelines on payload management to ensure that the robot arm operates within its design limits. By carefully selecting the appropriate payload and distributing it evenly, we can minimize the impact of the payload on the arm's inertia.
Conclusion
Inertia is a critical factor that significantly impacts the performance and operation of a CNC robot arm. By understanding the concept of inertia and the factors influencing it, manufacturers can optimize the design and performance of their robot arms to achieve superior productivity, precision, and energy efficiency. As a [company's role, e.g., "CNC robot arm supplier"], we are committed to providing our customers with high-quality robot arms that are designed to minimize inertia and deliver exceptional performance.
If you're in the market for a CNC Robot Arm, CNC Tending Robot, Loading and Unloading Robot, CNC Loading Robot, or Machine Tending Robot, we invite you to contact us to discuss your specific requirements. Our team of experts will be happy to assist you in selecting the right robot arm for your application and provide you with comprehensive support throughout the purchasing process.
References
- Dynamics of Machinery, Richard G. Budynas, J. Keith Nisbett
- Robotics: Modelling, Planning and Control, Bruno Siciliano, Lorenzo Sciavicco, Luigi Villani, Giuseppe Oriolo